01World models
Digital twins &
HD mapping
Reconstruct simulation-ready roads and lane-level vector maps from field and global geospatial data.
About
Ph.D. Researcher in Autonomous Driving Systems & Transportation Safety
I build learning, simulation, and mapping systems for safer and more capable autonomous vehicles.
I am a Ph.D. researcher in Civil and Environmental Engineering at Texas A&M University. My work spans autonomous-driving simulation, digital twins, HD map learning, vehicle control, V2X scenario generation, and safety analysis.
My goal is to work on autonomous driving systems that perform well not only in benchmarks, but also in the complexity of real traffic. My transportation-engineering background gives me a system-level perspective on how vehicles interact with roads, infrastructure, human drivers, and safety constraints.
Technical profile
Hao Zhang · AV systems researcher
Model the world→Generate hard cases→Design behavior→Measure safety
Reconstruct simulation-ready roads and lane-level vector maps from field and global geospatial data.
Build synchronized mixed-traffic worlds and turn road or language intent into repeatable critical tests.
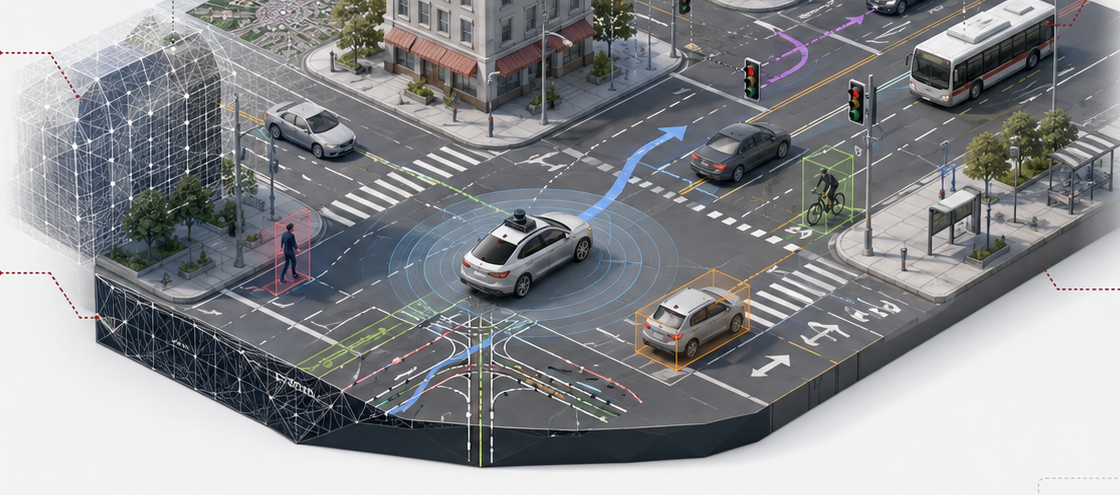
Design car-following and lane-change control across continuous and discrete actions.
Stress-test AVs in high-risk interactions with physics-aware, multidimensional, and stochastic methods.
Selected research
I focus on three practical bottlenecks for autonomous driving: building scalable world models, creating useful simulation scenarios, and evaluating safety under realistic traffic interactions.
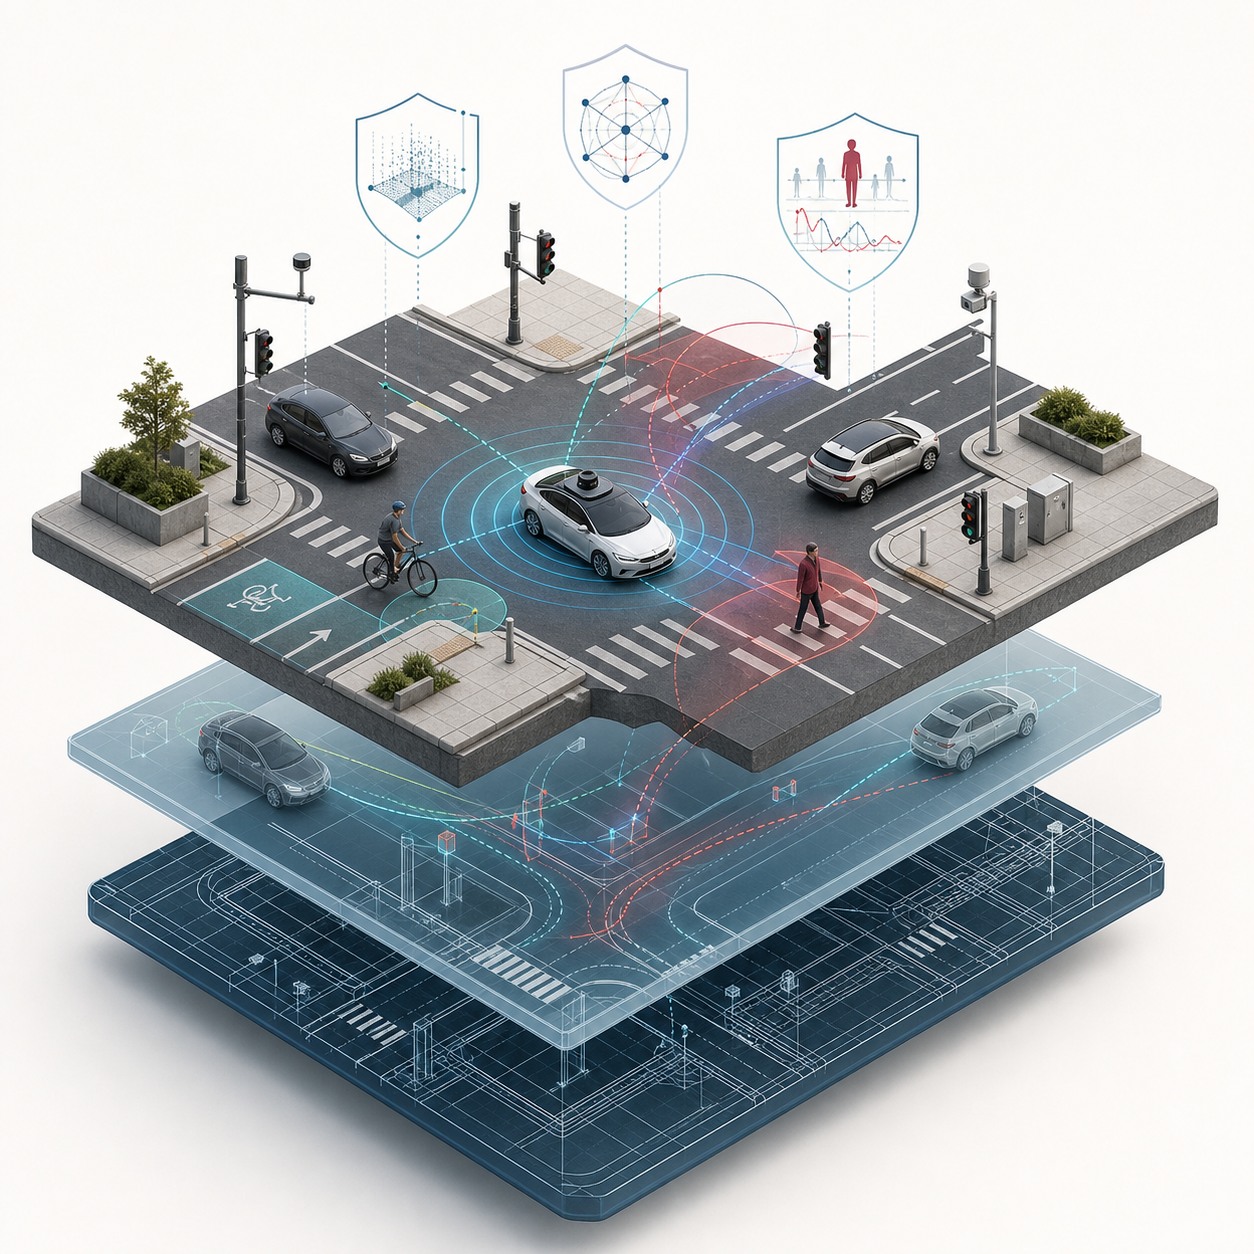
A digital-twin framework for reproducing mixed autonomous traffic and measuring safety with synchronized traffic flow, vehicle physics, and perception-level simulation.
It provides a scenario-to-metric workflow for testing vehicle behavior under realistic geometry, traffic demand, and physical conditions.
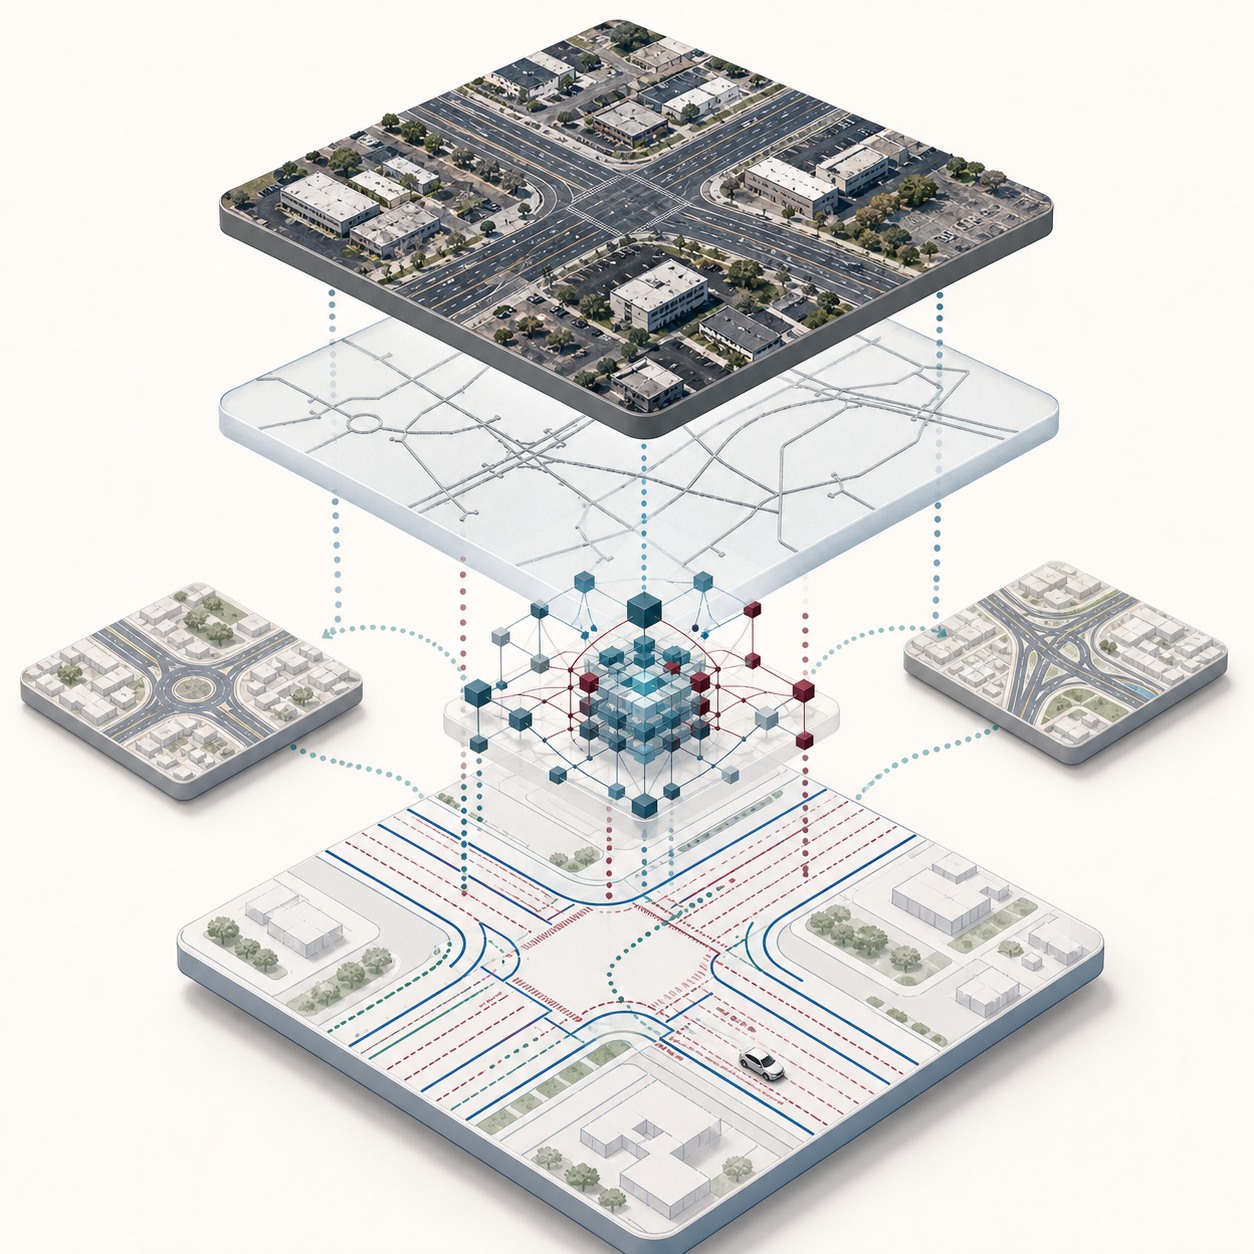
A multi-modal learning framework that transforms satellite imagery and imperfect OpenStreetMap priors into lane-level vector maps with geometry, semantics, and topology.
It explores a scalable route for bootstrapping and updating HD map coverage without relying exclusively on repeated survey-vehicle collection.
An LLM-orchestrated, retrieval-augmented framework that converts natural-language traffic intent into communication-aware CARLA scenarios with executable behavior and V2X fault models.
It reduces the effort required to author diverse simulation scenarios and links communication failures—latency, loss, and jitter—to driving safety outcomes.
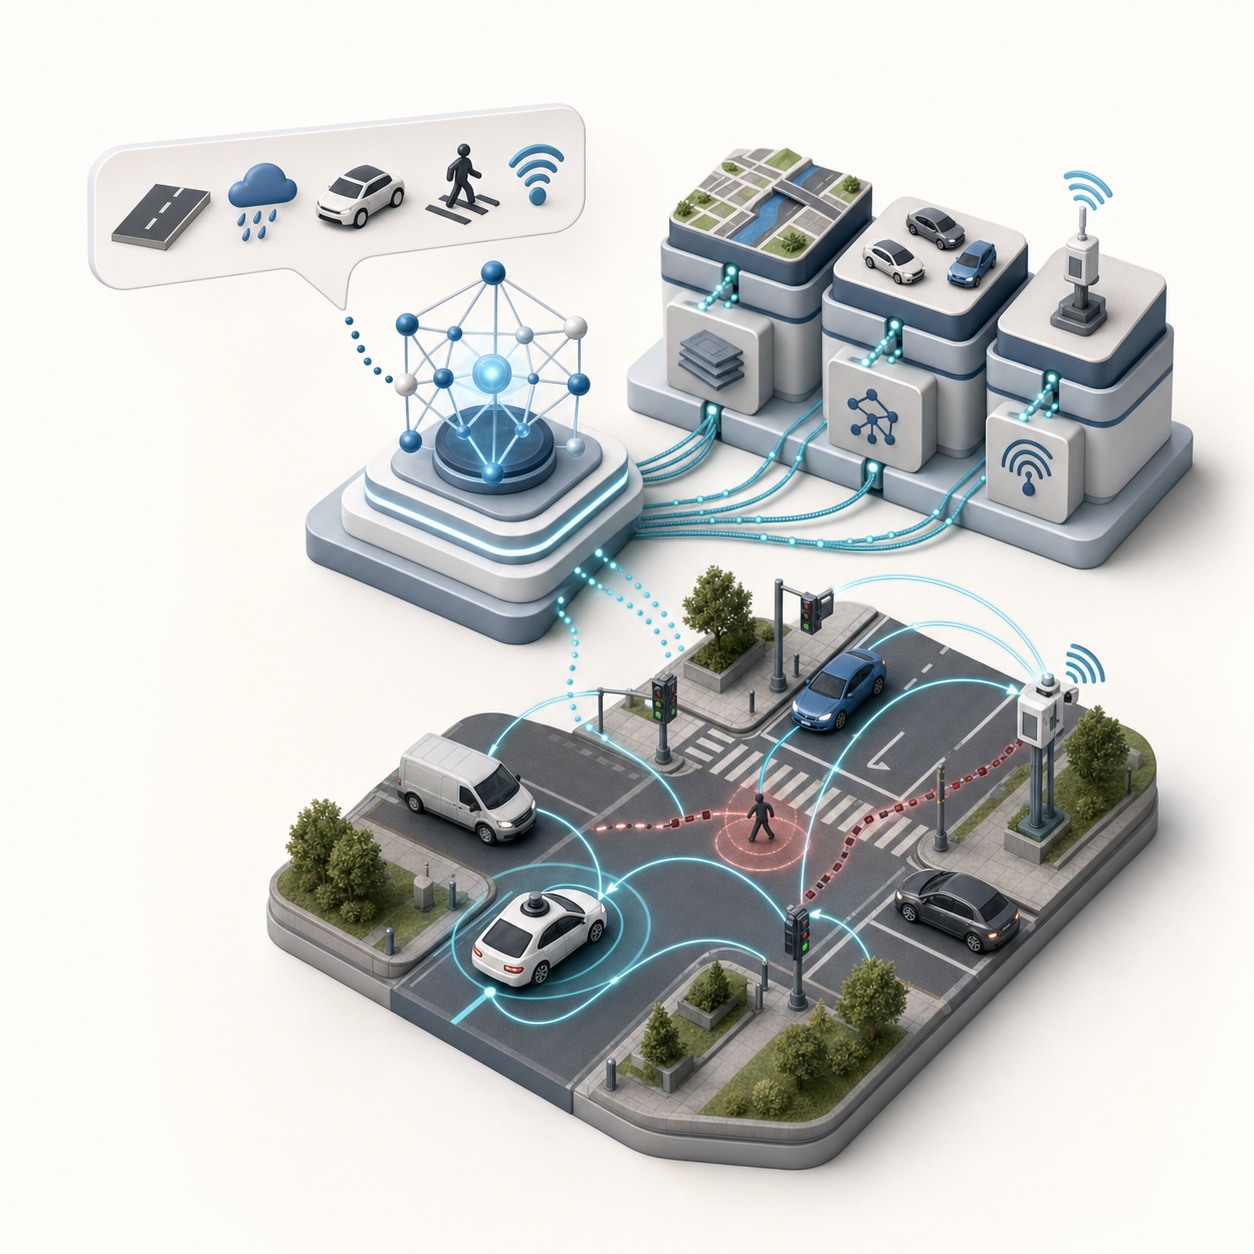
Describe the traffic, agents, environment, and communication conditions.
Retrieve validated behaviors, maps, and V2X modules.
Run the scenario and collect joint mobility and message telemetry.
Publications
H. Zhang, Z. Li, and Y. Zhou
arXiv preprintH. Zhang, X. Yue, K. Tian, S. Li, K. Wu, Z. Li, D. Lord, and Y. Zhou
IEEE Internet of Things JournalH. Zhang, S. Li, Z. Li, M. Anis, D. Lord, and Y. Zhou
Accident Analysis & PreventionH. Zhang, K. Wu, Z. Li, Z. Tu, D. Lord, and Y. Zhou
Presented at TRB 2026K. Wu, H. Zhang, P. Li, R. Gan, J. You, Z. Tu, and Y. Zhou
Presented at TRB 2026H. Zhang, Y. Zou, X. Yang, and H. Yang
NeurocomputingBackground
Ph.D. in Civil and Environmental Engineering
Research / Teaching Assistant · 2023–PresentM.S. in Transportation Engineering
Research Assistant · 2020–2023B.S. in Logistics Engineering
2016–2020Contact
I welcome conversations about AV simulation, mapping, safety validation, and intelligent mobility systems.
haozhangch9811@gmail.com